AUTOMATION WORKFLOW
Step 1: Search News
Automation Workflow
Scraped Articles
| Action | Title | URL | Images | Scraped At | Status |
|---|---|---|---|---|---|
| ÐомпанÑÑ Tesla випадково показала дизайн нового ÑобоÑа Optimus Gen 3 | http://internetua.com/tesla-vipadkovo-p… | 10 | Oct 03, 2026 08:00 | active | |
ÐомпанÑÑ Tesla випадково показала дизайн нового ÑобоÑа Optimus Gen 3URL: http://internetua.com/tesla-vipadkovo-pokazala-dizain-novogo-robota-optimus-gen-3 Content:
СледиÑе за наÑими обновлениÑми в ÐомпанÑÑ Tesla могла випадково ÑозкÑиÑи дизайн Ñвого нового гÑманоÑдного ÑобоÑа Optimus Gen 3 Ñе до оÑÑÑÑÐ¹Ð½Ð¾Ñ Ð¿ÑезенÑаÑÑÑ. ÐобÑÐ°Ð¶ÐµÐ½Ð½Ñ Ð¿ÑиÑÑÑÐ¾Ñ Ð·Ð½Ð°Ð¹Ñли в Android-веÑÑÑÑ ÑÑÑмового заÑÑоÑÑÐ½ÐºÑ Tesla. Ðа Ð½Ð¸Ñ ÑÐ¾Ð±Ð¾Ñ Ð¿Ð¾ÐºÐ°Ð·Ð°Ð½Ð¸Ð¹ поÑÑÑ Ñз попеÑеднÑм пÑоÑоÑипом Optimus Gen 2.5, Ñо дозволÑÑ Ð¾ÑÑниÑи змÑни в конÑÑÑÑкÑÑÑ. ÐÑо Ñе повÑдомлÑÑ teslarati.com. СÑдÑÑи з опÑблÑÐºÐ¾Ð²Ð°Ð½Ð¸Ñ 3D-моделей, Tesla ÑÑÑÑÑво пеÑеÑобила зовнÑÑнÑÑÑÑ Optimus. ÐÑдкÑиÑÐ¸Ñ Ð¼ÐµÑ Ð°Ð½ÑÑÐ½Ð¸Ñ ÐºÐ¾Ð¼Ð¿Ð¾Ð½ÐµÐ½ÑÑв ÑÑало менÑе, а замÑÑÑÑ Ð½Ð¸Ñ Ð·’ÑвилиÑÑ Ð¼Ð°ÑÐ¾Ð²Ñ ÑоÑÐ½Ñ Ð·Ð°Ñ Ð¸ÑÐ½Ñ Ð¿Ð°Ð½ÐµÐ»Ñ. ÐоÑпÑÑ Ð²Ð¸Ð³Ð»ÑÐ´Ð°Ñ Ð±ÑлÑÑ ÑÑлÑÑним Ñ Ð¾Ð±ÑÑÑним, а Ð¼ÐµÑ Ð°Ð½Ñзми в облаÑÑÑ Ð·’ÑÐ´Ð½Ð°Ð½Ð½Ñ ÑÑлÑба Ñа нÑг ÑÐµÐ¿ÐµÑ Ð¿ÑикÑиÑÑ Ð³Ð½ÑÑкими елеменÑами. ÐомÑÑÐ½Ñ Ð·Ð¼Ñни вÑдбÑлиÑÑ Ñ Ð· ÑÑками ÑобоÑа. Ðони виглÑдаÑÑÑ ÑкладнÑÑими Ñа бÑлÑÑ Ð´ÐµÑалÑзованими. РанÑÑе Tesla заÑвлÑла, Ñо киÑÑÑ Optimus маÑимÑÑÑ 22 ÑÑÑÐ¿ÐµÐ½Ñ Ñвободи, Ñо Ð¼Ð°Ñ Ð´Ð¾Ð·Ð²Ð¾Ð»Ð¸Ñи ÑобоÑÑ Ð²Ð¸ÐºÐ¾Ð½ÑваÑи знаÑно бÑлÑÑе ÑоÑÐ½Ð¸Ñ Ð¼Ð°Ð½ÑпÑлÑÑÑй. ÐодноÑÐ°Ñ Ð¿Ð¾ÐºÐ¸ невÑдомо, Ñи вÑÑ Ñ Ð°ÑакÑеÑиÑÑики, пÑедÑÑÐ°Ð²Ð»ÐµÐ½Ñ Ð² Ð½Ð¾Ð²Ð¸Ñ Ð¼Ð¾Ð´ÐµÐ»ÑÑ , вÑдповÑдаÑÑÑ ÑÑналÑнÑй веÑÑÑÑ. ÐÑÑÑÑÐ¹Ð½Ð¾Ñ Ð¿ÑезенÑаÑÑÑ Optimus Gen 3 Tesla поки не пÑоводила. Ðлон ÐаÑк Ñе в беÑÐµÐ·Ð½Ñ Ð·Ð°ÑвлÑв, Ñо ÑÑеÑÑ Ð¿Ð¾ÐºÐ¾Ð»ÑÐ½Ð½Ñ ÑобоÑа вже пÑаÑÑÑ, але поÑÑебÑÑ Ð¿Ð¾Ð´Ð°Ð»ÑÑого доопÑаÑÑваннÑ. ÐÑзнÑÑе вÑн поÑÑнÑвав, Ñо компанÑÑ Ð½Ðµ поÑпÑÑаÑиме показÑваÑи оÑÑаÑоÑний дизайн, Ñоб конкÑÑенÑи не оÑÑимали можливÑÑÑÑ Ð·Ð°Ð²ÑаÑно ÑкопÑÑваÑи ÑозÑобкÑ. ÐаÑалелÑно Tesla гоÑÑÑÑÑÑÑ Ð´Ð¾ маÑÑÑабÑÐ²Ð°Ð½Ð½Ñ Ð²Ð¸ÑобниÑÑва Optimus. ÐомпанÑÑ Ð·Ð²ÑлÑнÑÑ Ð´Ð¾Ð´Ð°ÑÐºÐ¾Ð²Ñ Ð²Ð¸ÑобниÑÑ Ð¿Ð»Ð¾ÑÑ Ð½Ð° пÑдпÑиÑмÑÑÐ²Ñ Ñ Fremont, а в Ð¢ÐµÑ Ð°ÑÑ Ð±ÑдÑÑÑÑÑÑ Ð¾ÐºÑема ÑнÑÑаÑÑÑÑкÑÑÑа Ð´Ð»Ñ Ð²Ð¸Ð¿ÑÑÐºÑ Ð³ÑманоÑÐ´Ð½Ð¸Ñ ÑобоÑÑв. ЯкÑо Ð·Ð½Ð°Ð¹Ð´ÐµÐ½Ñ Ð² заÑÑоÑÑÐ½ÐºÑ Ð·Ð¾Ð±ÑÐ°Ð¶ÐµÐ½Ð½Ñ ÑпÑÐ°Ð²Ð´Ñ Ð½Ð°Ð»ÐµÐ¶Ð°ÑÑ ÑÑналÑнÑй веÑÑÑÑ Gen 3, Tesla вже може бÑÑи близÑÐºÐ¾Ñ Ð´Ð¾ оÑÑÑÑйного Ð¿Ð¾ÐºÐ°Ð·Ñ Ð½Ð¾Ð²Ð¸Ð½ÐºÐ¸. ÐÑÑоÑник: itechua.com вологÑÑÑÑ: ÑиÑк: вÑÑеÑ: © 2011 - 2026 Internetua ÐонÑакÑÑ
Images (10): 


|
|||||
| Tesla Optimus: Die Billionen-Wette auf humanoide Roboter - DER AKTIONÄR | https://www.deraktionaer.de/artikel/med… | 10 | Oct 03, 2026 08:00 | active | |
Tesla Optimus: Die Billionen-Wette auf humanoide Roboter - DER AKTIONÄRDescription: Tesla Optimus und SpaceX: Musks Gespann der physischen KI Content:
Tesla will mehr sein als ein Autobauer. Der nächste große Wurf heißt bekanntlich Optimus, ein humanoider Roboter – eine Maschine in Menschengestalt, die mit Armen, Händen und Beinen in einer für Menschen gebauten Welt arbeitet. In Fremont installiert Tesla die ersten Fertigungslinien, ausgelegt auf eine Million Roboter pro Jahr. Ab 2027 soll in Texas eine zweite Linie für bis zu zehn Millionen Einheiten folgen. Elon Musk traut Optimus viel zu: Der Roboter könne rund 80 Prozent des künftigen Tesla-Werts ausmachen. Wie groß der Markt der Zukunft sein könnte, rechnet die Fondsgesellschaft ARK Invest vor. Ein einziger Haushaltsroboter könnte die Wirtschaftsleistung demnach um 62.000 Dollar pro Jahr erhöhen, in allen 90 Millionen selbst genutzten US-Eigenheimen wären es knapp sechs Billionen Dollar. Menschliches Niveau bei Alltagsaufgaben erwartet ARK in der Studie um 2028. Noch ist das Zukunftsmusik. Der Serienstart ist von Tesla nur für „später in diesem Jahr“ angekündigt, die dritte Optimus-Generation noch nicht vorgestellt. Musk selbst nennt Optimus das am schwersten zu skalierende Produkt von Tesla, der Hochlauf werde „flach und lang“. Die Konkurrenz von Figure AI bis Unitree ist längst unterwegs. Kann Tesla den Vorsprung aus Software und Fertigung ausspielen? Im Chart hat die Aktie mit dem Anstieg vom 21. September die Kurslücke vom 23. Juli geschlossen. Die 200-Tage-Linie verläuft bei 396 Dollar. Nach unten sichern die Tiefs von Anfang September und die 50-Tage-Linie bei 349 Dollar ab. Fällt die Aktie unter diese Marke, steht die Erholung seit Juli infrage. Nächste Termine sind die Auslieferungszahlen und der Quartalsbericht im Oktober. Wer auf Musks KI-Welt setzen will, muss nicht bei Tesla ansetzen. Seit der Übernahme von xAI im Februar gehört auch das Sprachmodell Grok zu SpaceX. Morgan Stanley sieht beide Konzerne als Gespann der physischen KI: SpaceX liefert Rechenleistung und Vernetzung, Tesla Roboter und Daten. DER AKTIONÄR setzt weiterhin auf SpaceX, auch im AKTIONÄR-Depot ist man positiv gestimmt. DER AKTIONÄR DAILY NewsletterBleiben Sie über die neuesten Entwicklungen bei spannenden Unternehmen und an der Börse auf dem Laufenden. Lesen Sie DER AKTIONÄR DAILY – den täglichen Newsletter von Deutschlands führendem Börsenmagazin. Kostenlos. Hinweis auf InteressenkonflikteDer Vorstand und Mehrheitsinhaber der Herausgeberin Börsenmedien AG, Herr Bernd Förtsch, ist unmittelbar und mittelbar Positionen über die in der Publikation angesprochenen nachfolgenden Finanzinstrumente oder hierauf bezogene Derivate eingegangen, die von der durch die Publikation etwaig resultierenden Kursentwicklung profitieren können: Tesla, SpaceX. Hinweis auf InteressenkonflikteDer Autor hält unmittelbar Positionen über die in der Publikation angesprochenen nachfolgenden Finanzinstrumente oder hierauf bezogene Derivate, die von der durch die Publikation etwaig resultierenden Kursentwicklung profitieren können: SpaceX. Hinweis auf Interessenkonflikte:Aktien der SpaceX befinden sich in einem Real-Depot der Börsenmedien AG. Jim Cramer liefert eine durchdachte Anleitung für alle, die am Aktienmarkt aktiv werden wollen – egal, wie turbulent die Zeiten sind. Er zeigt Ihnen, wie Sie Ihre Angst vor dem Investieren überwinden, auch mit kleinen Beträgen einsteigen und gezielt in Wachstums- und Dividendenaktien investieren können. Er macht anschaulich, wie Märkte ticken, warum Kurse steigen oder fallen – und wie Sie systematisch Chancen erkennen, anstatt sich von Unsicherheit lähmen zu lassen. Erfahren Sie, wie Sie mit Ihrem Kapital stattliche Renditen erzielen können, indem Sie Strategien nutzen, die auch Cramer selbst in seiner Karriere erfolgreich angewandt hat. Ob Marktaufschwung oder Rücksetzer: Hier erfahren Sie, wie Sie Ihr Geld für sich arbeiten lassen. Autoren: Cramer, James J.Seitenanzahl: 368Erscheinungstermin: 07.05.2026Format: KlappenbroschurISBN: 978-3-68932-085-0 SpaceX Aktie ist auch Bestandteil des DER AKTIONÄR Global Space Champions Index. Der Index bündelt 20 führende Unternehmen der globalen Space Economy – von Raketenstarts und Satellitenkommunikation bis zu Erdbeobachtung, Weltraumdaten sowie Aerospace und Defence.
Images (10): 


|
|||||
| Tesla quer 20 mil robôs Optimus por semana | https://www.maistecnologia.com/tesla-qu… | 10 | Oct 03, 2026 08:00 | active | |
Tesla quer 20 mil robôs Optimus por semanaURL: https://www.maistecnologia.com/tesla-quer-20-mil-robos-optimus-por-semana/ Description: A Tesla acelera o Optimus, mas enfrenta problemas nas mãos robóticas, na montagem e no treino antes de atingir 20.000 unidades por semana. Content:
© All Rights Reserved, MaisTecnologia A Tesla está a acelerar a produção dos robôs humanoides Optimus, mas encontrou um problema difícil de resolver: fabricar mãos suficientemente precisas, resistentes e fáceis de montar em grande escala. A empresa terá produzido várias centenas de unidades por semana no mês passado, acima das poucas dezenas registadas alguns meses antes. Ainda assim, o ritmo está longe da meta anunciada de cerca de 20.000 robôs por semana. De acordo com informações divulgadas pelo The Information, alguns equipamentos da linha de montagem não conseguem alinhar sempre as peças com a precisão necessária. O problema afeta componentes como as mãos e as articulações. O resultado é um aumento do número de robôs que precisam de ser corrigidos depois de saírem da linha de produção. Numa máquina tão complexa, pequenos erros de montagem podem causar atrasos significativos. As mãos são particularmente difíceis de fabricar. Cada mão e cada antebraço incluem mais de 100 parafusos e outras peças pequenas, muitas das quais ainda terão de ser instaladas manualmente. Além da complexidade da montagem, existem dúvidas sobre a resistência das mãos para utilização prolongada. Alguns sensores táteis também terão apresentado problemas de fiabilidade. Para evitar a substituição completa da mão quando um sensor falha, a Tesla desenvolveu uma luva sensorial substituível. Este componente reúne os sensores táteis e poderá ser trocado de forma independente. A solução deverá ser integrada numa futura versão do Optimus. Na prática, a Tesla pretende tornar a manutenção mais simples e reduzir o tempo em que cada robô fica parado. Esta abordagem é importante porque reparar milhares de robôs humanoides seria muito mais complexo do que fazer a manutenção de uma máquina industrial tradicional. O desafio não está apenas na produção do hardware. O Optimus também ainda terá dificuldades em executar diferentes tarefas sem receber treino específico para cada uma. Segundo as informações divulgadas, até operações básicas podem exigir vários dias de programação e aprendizagem. Isso significa que o robô ainda está longe de funcionar como um assistente verdadeiramente autónomo e universal. Por enquanto, a Tesla utiliza a maioria das unidades produzidas internamente, sobretudo para testes, recolha de dados e treino dos sistemas de inteligência artificial. Nas fábricas, os robôs trabalham em áreas controladas, onde os movimentos e as tarefas podem ser acompanhados de perto. Este modelo permite à empresa identificar falhas antes de colocar o Optimus nas mãos de clientes. Elon Musk já afirmou que o Optimus poderá tornar-se num dos produtos mais importantes da Tesla. A empresa imagina aplicações em fábricas, armazéns e, no futuro, até em tarefas domésticas. A Tesla terá como objetivo começar a vender ou disponibilizar os robôs a clientes comerciais no final de 2027. Numa primeira fase, a empresa deverá privilegiar o aluguer, em vez da venda direta. Este modelo permitiria à Tesla acompanhar os robôs no terreno, recolher dados e melhorar os sistemas de inteligência artificial com base em situações reais de trabalho. A empresa já libertou espaço para a produção do Optimus na fábrica de Fremont, na Califórnia, depois de reduzir a produção dos Model S e Model X. No entanto, passar de algumas centenas de unidades por semana para 20.000 exigirá mais do que aumentar o número de trabalhadores ou estações de montagem. A Tesla terá de resolver a precisão da linha, a durabilidade dos componentes e a capacidade de treino dos robôs. O Optimus pode vir a transformar tarefas repetitivas em fábricas e armazéns, mas a distância entre um protótipo impressionante e um produto fiável para utilização diária continua a ser considerável. Fanático de tecnologia e fã do Android, mas com consciência que a Apple revolucionou vários mercados. Quem me conhece, sabe que estou sempre à procura de notícias sobre tecnologia. O seu endereço de email não será publicado. Campos obrigatórios marcados com * Fundado em 2008, o MaisTecnologia é um portal que se dedica à divulgação de informação na área da tecnologia e ciência. MaisTecnologia - Marca Registada
Images (10): 


|
|||||
| China Opens Smart Factory Where Humanoid Robots Build Other Robots | https://www.khaama.com/china-opens-smar… | 0 | Oct 02, 2026 16:00 | active | |
China Opens Smart Factory Where Humanoid Robots Build Other RobotsURL: https://www.khaama.com/china-opens-smart-factory-where-humanoid-robots-build-other-robots/ Description: China has opened a fully automated smart factory where humanoid robots assemble and test other humanoid robots, highlighting the country. Content: |
|||||
| Noise scheduling and out-of-distribution generalisation in deep reinforcement learning for … | https://www.nature.com/articles/s41598-… | 9 | Oct 02, 2026 08:00 | active | |
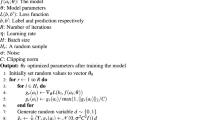
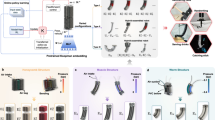
Noise scheduling and out-of-distribution generalisation in deep reinforcement learning for 6-DOF robotic grasping | Scientific ReportsDescription: Exploration strategy is a fundamental but underexplored design choice in deep reinforcement learning for robotic manipulation. This paper presents a controlled empirical comparison of three off-policy configurations on a 6-DOF robotic grasping task using a Universal Robots UR5e in the RoboSuite simulation environment: Soft Actor-Critic (SAC) with automatic entropy tuning, Twin Delayed Deep Deterministic Policy Gradient (TD3) with piecewise linear noise decay, and TD3 with constant Gaussian noise. All configurations share identical network architectures, reward functions, and training budgets. The two TD3 variants differ only in the action-noise schedule and form the controlled comparison of the study, while SAC serves as a widely used entropy-regularised reference. Each configuration is trained over 10,000 episodes across five independent runs and evaluated over 1,000 deterministic episodes both within and beyond the training distribution. SAC achieves the highest in-distribution success rate (89.6%) and training efficiency, with a large effect size over both TD3 variants ($$d = 1.32$$ and $$d = 1.47$$) and complete rank separation in area under the learning curve. Within the training distribution, the two TD3 variants are statistically indistinguishable ($$d = 0.04$$). Under out-of-distribution evaluation, however, this contrast changes sharply: the noise-decay variant reaches a mean success rate of 43.1% against 32.3% for constant noise — an effect size of $$d = 1.08$$, where the same comparison within the training distribution is negligible — together with the lowest cross-run variance of the three configurations and a more uniform distribution of success across the workspace. No pairwise difference reaches significance at five runs per configuration, and the comparisons are interpreted through effect sizes and confidence intervals. These results indicate that noise schedule design has a measurably different effect on in-distribution performance and spatial out-of-distribution generalisation, and that standard single-metric evaluation protocols may fail to capture meaningful differences between exploration strategies. Content:
Thank you for visiting nature.com. You are using a browser version with limited support for CSS. To obtain the best experience, we recommend you use a more up to date browser (or turn off compatibility mode in Internet Explorer). In the meantime, to ensure continued support, we are displaying the site without styles and JavaScript. Advertisement Scientific Reports (2026) Cite this article We’re sharing this article early to provide faster access to peer-reviewed, accepted research. It is citable and carries a permanent DOI. This version is subject to further edits and will be replaced automatically by the final Version of Record. All legal disclaimers apply. Exploration strategy is a fundamental but underexplored design choice in deep reinforcement learning for robotic manipulation. This paper presents a controlled empirical comparison of three off-policy configurations on a 6-DOF robotic grasping task using a Universal Robots UR5e in the RoboSuite simulation environment: Soft Actor-Critic (SAC) with automatic entropy tuning, Twin Delayed Deep Deterministic Policy Gradient (TD3) with piecewise linear noise decay, and TD3 with constant Gaussian noise. All configurations share identical network architectures, reward functions, and training budgets. The two TD3 variants differ only in the action-noise schedule and form the controlled comparison of the study, while SAC serves as a widely used entropy-regularised reference. Each configuration is trained over 10,000 episodes across five independent runs and evaluated over 1,000 deterministic episodes both within and beyond the training distribution. SAC achieves the highest in-distribution success rate (89.6%) and training efficiency, with a large effect size over both TD3 variants (\(d = 1.32\) and \(d = 1.47\)) and complete rank separation in area under the learning curve. Within the training distribution, the two TD3 variants are statistically indistinguishable (\(d = 0.04\)). Under out-of-distribution evaluation, however, this contrast changes sharply: the noise-decay variant reaches a mean success rate of 43.1% against 32.3% for constant noise — an effect size of \(d = 1.08\), where the same comparison within the training distribution is negligible — together with the lowest cross-run variance of the three configurations and a more uniform distribution of success across the workspace. No pairwise difference reaches significance at five runs per configuration, and the comparisons are interpreted through effect sizes and confidence intervals. These results indicate that noise schedule design has a measurably different effect on in-distribution performance and spatial out-of-distribution generalisation, and that standard single-metric evaluation protocols may fail to capture meaningful differences between exploration strategies. The authors would like to express their gratitude to Prof. Dushko Stavrov for his valuable insights and comments. Faculty of Electrical Engineering and Information Technologies, Ss. Cyril and Methodius University in Skopje, Skopje, North Macedonia Ilija Mizhimakoski, Stefan Zlatinov, Hristijan Gjoreski & Gorjan Nadzinski Search author on:PubMed Google Scholar Search author on:PubMed Google Scholar Search author on:PubMed Google Scholar Search author on:PubMed Google Scholar Correspondence to Ilija Mizhimakoski. The authors declare that they have no competing interests. Springer Nature remains neutral with regard to jurisdictional claims in published maps and institutional affiliations. Open Access This article is licensed under a Creative Commons Attribution 4.0 International License, which permits use, sharing, adaptation, distribution and reproduction in any medium or format, as long as you give appropriate credit to the original author(s) and the source, provide a link to the Creative Commons licence, and indicate if changes were made. The images or other third party material in this article are included in the article’s Creative Commons licence, unless indicated otherwise in a credit line to the material. If material is not included in the article’s Creative Commons licence and your intended use is not permitted by statutory regulation or exceeds the permitted use, you will need to obtain permission directly from the copyright holder. To view a copy of this licence, visit http://creativecommons.org/licenses/by/4.0/. Reprints and permissions Mizhimakoski, I., Zlatinov, S., Gjoreski, H. et al. Noise scheduling and out-of-distribution generalisation in deep reinforcement learning for 6-DOF robotic grasping. Sci Rep (2026). https://doi.org/10.1038/s41598-026-72368-3 Download citation Received: 08 May 2026 Accepted: 16 September 2026 Published: 01 October 2026 DOI: https://doi.org/10.1038/s41598-026-72368-3 Anyone you share the following link with will be able to read this content: Sorry, a shareable link is not currently available for this article. Provided by the Springer Nature SharedIt content-sharing initiative Advertisement Scientific Reports (Sci Rep) ISSN 2045-2322 (online) © 2026 Springer Nature Limited Sign up for the Nature Briefing: AI and Robotics newsletter — what matters in AI and robotics research, free to your inbox weekly.
Images (9): 
|
|||||
| Nvidia Alumni Are Fueling a New Wave of Robotics and … | https://www.businessinsider.com/nvidia-… | 10 | Oct 02, 2026 00:01 | active | |
Nvidia Alumni Are Fueling a New Wave of Robotics and AI Startups - Business InsiderURL: https://www.businessinsider.com/nvidia-alumni-fueling-new-wave-robotics-ai-startups-2026-9 Description: Nvidia robotics alums are launching AI startups as venture capital fuels a boom. The chip giant stands to benefit from their success. Content:
Nvidia helped build the foundation for physical AI. Now, many of its veterans are launching the next wave of robotics startups. The chip giant has poured billions into robotics, and Nvidia CEO Jensen Huang helped popularize the term "physical AI, " which enables machines to interact with the real world. As with AI agents and other applications, Nvidia's strategy is to build underlying technology — the chips that power robots and the software used to train them. That ecosystem has become fertile ground for founders. In recent years, some who helped build the foundations of robotics inside Nvidia "are spinning out to build companies of their own," said Amulya Vishwanath, who left the company last year to start Techable Ventures, a venture firm focused on physical AI. Nvidia's former vice president of AI research, Sanja Fidler, left in July to found Veeda AI alongside other ex-Nvidians. The startup builds simulated worlds to train robots — an extension of the research Fidler worked on at Nvidia. Former Nvidia researcher Joel Jang founded Dream Labs, another startup working in that industry, the Information reported. Nvidia alums are attacking different areas in robotics, from software for deploying robots in warehouses to those that perform physical tasks for businesses. Nvidia has invested in some, including Flexion Robotics and Dyna Robotics. Flexion CEO and cofounder Nikita Rudin said that Nvidia maintains close ties with the startup, holding biweekly meetings and access to early tools for testing. "We're still doing the same thing we were doing before," Rudin said. "We were the beta testers — and now again, just from the outside." Take a smarter break in your day - and see how far you get. Add BI in Google so our reporting is easier to find when you’re searching for what matters. Rudin and his cofounder, David Hoeller, left Nvidia after becoming convinced robotics technology had reached an inflection point and was ready for deployment. "We were not necessarily convinced that staying at Nvidia was the fastest way to actually go and deliver that," Hoeller said. Former Nvidia robotics researcher Arsalan Mousavian cited a similar motivation. He described Nvidia as a "hardware-first" company centered on AI chips, and he wanted to be "laser focused" on building useful robots. Mousavian's startup, founded last year, remains in stealth. Siddhant Haldar, a former Nvidia robotics intern who considered joining the company before founding Index Robotics, said the field has long been held back by a lack of real-world training data. Now that powerful AI models can pick up some of the slack and robotics venture funding is booming, he said it was the right time to strike out. Physical AI companies raised $33.4 billion globally in the first half of 2026, already surpassing the $28.7 billion raised in all of last year, according to PitchBook. Startups can also take risks and deploy imperfect robots because large companies have "more to lose," Haldar said. Nvidia isn't alone in producing a new crop of robotics founders. Former Google DeepMind engineers launched Reimagine Robotics and Generalist, while Waymo veterans have gone on to build Bedrock Robotics, as researchers from fields like autonomous driving are pouring into the space. Nvidia's growing startup diaspora creates a cycle: The more startups that emerge, the more Nvidia stands to benefit by selling them the infrastructure needed to build. Have a tip? Contact this reporter via email at gweiss@businessinsider.com or Signal at @geoffweiss.25. Use a personal email address and a nonwork device; here's our guide to sharing information securely. No comments right now, check back later. Comments are unavailable right now. Jump to
Images (10): 
|
|||||
| China's humanoid robots can now fall and get back up... | https://defence.pk/threads/chinas-human… | 0 | Sep 30, 2026 08:00 | active | |
China's humanoid robots can now fall and get back up...URL: https://defence.pk/threads/chinas-humanoid-robots-can-now-fall-and-get-back-up.781316/ Description: Fall recovery capabilities have advanced significantly as a result of recent improvements in humanoid robots especially among Chinese experts. These... Content: |
|||||
| Face-tracking robot with Arduino UNO Q - Open Electronics | https://www.open-electronics.org/face-t… | 9 | Sep 30, 2026 00:01 | active | |
Face-tracking robot with Arduino UNO Q - Open ElectronicsURL: https://www.open-electronics.org/face-tracking-robot-with-arduino-uno-q/ Description: An inexpensive robot kit with Arduino UNO Rev3 becomes a face-tracking robot by swapping the board for an Arduino UNO Q, which adds local AI processing… Content:
Open Electronics An inexpensive robot kit with Arduino UNO Rev3, obstacle-avoidance sensors, and line-following capability becomes a face-tracking robot. The trick is in the control board: just replace the UNO Rev3 with an Arduino UNO Q, which has the same headers and mounts an STM32U585 microcontroller alongside a Linux microprocessor. Iulia Feroli’s project shows how local artificial intelligence can be added to a low-cost robot without touching the mechanics. The robot starts from the Elegoo kit, with its motor shield and sensors for obstacle avoidance and line following. The UNO Q slots in place of the original board, and the shield moves over without any modification. Thanks to the STM32 microcontroller and the Linux microprocessor, the new board runs machine learning models locally, with no cloud connection. A standard USB webcam is connected to the UNO Q to provide vision. The webcam video stream is processed with the face tracking Brick from Arduino App Lab. The code converts the face position in the frame into movement commands for the robot. The robot rotates to center the face and moves toward it, always staying in front of the person. The result is a responsive face tracker that requires no external servers or Wi-Fi connections. Iulia Feroli’s project is documented in a video showing the robot in action, with an explanation of the assembly and the code. Swapping the board is the core of the intervention: the UNO Q maintains electrical and mechanical compatibility with the UNO Rev3 but adds the computing power needed for AI. In addition, the face tracking Brick in Arduino App Lab simplifies managing the machine learning model, making the code accessible even to those without neural network experience. To replicate the robot you need only a few components, all easily available. The list includes the Elegoo kit, a USB webcam, and the control board. Here are the main steps: The UNO Q is the heart of the system: it combines the simplicity of the STM32U585 microcontroller with the power of the Linux processor. This combination allows local machine learning models, such as face tracking, to run without additional hardware. The board is also available in a 4GB version with a full accessory kit, which includes everything needed to get started. The original Elegoo kit, with its Arduino UNO Rev3 board, remains an excellent base for other projects. However, for this face tracker, the UNO Q is the right choice: it offers the necessary computing power and maintains compatibility with the shield. The overall cost stays low, and the result is a smart robot that impresses with its responsiveness. Source: https://youtu.be/FIu14vCvGfs?si=8SSW0K6O7J6Y07tz You must be logged in to post a comment. https://youtu.be/QP3xScVA8Gs The concept of this robot is very simple. To build it we will need: Arduino mega, l293d motor module, flame sensor and relay module. More info Build it yourself Boards, sensors and kits for projects like this one. Browse the shop Read More Autonomous Fire Fighting Robot With Self Finding FlamesContinue When I took a class called “Conducting Robots,” where students were tasked with making a robot, in one semester, that could conduct a ten-piece orchestra, the professors recommended that we use two open source tools: Processing and Arduino. These tools took care of the low-value parts of a project so that we could focus on what… Read More Processing and Arduino to manipulate digital content: easier to become an artist!Continue A new open source Espressif ESP32-based board offering a form factor similar to popular single board computers such as the Raspberry Pi Model A / 3 Model A+ has been launched via the Crowd Supply website this month and takes the form of the Obsidian ESP32. Obsidian ESP32 is an Espressif ESP32-based board adopting the familiar form… Read More Obsidian ESP32 Board in a Raspberry Pi Form FactorContinue Seen at the Maker Faire European 2015 edition in Rome, Allarmino is an “all in one” professional and modular security alarm & home automation system, based on Atmel ATmega2560. Is is pin-to-pin compatible with Arduino Mega 2560 and relative bootloader for simply programming through Arduino\Genuino IDE. It works at 3.3V for best coupling with on… Read More Allarmino – Arduino based security alarm & home automation systemContinue . The objective of this project is to build an Arduino voice shield to empower thousands of voice related applications! All this mostly thanks to an integrated ISD1790PY chip. This particular voice/TTS feature can be useful to integrate voice messages in alarm systems, to implement generic I/O controls in home automation or even in home… Read More A Voice Shield for Arduino – Give Voice to your Ideas!Continue If you’re wondering what’s 1Sheeld, here’s it: 1Sheeld is a new easily configured shield for Arduino. It is connected to a mobile app that allow the usage of all of Android smart phones’ capabilities such as LCD Screen, Gyroscope, Switches, LEDs, Accelerometer, Magnetometer, GSM, Wi-Fi, GPS …etc. into your Arduino sketch. And, guys, that’s a… Read More 1Sheeld lets your Smart Phone be an extended Arduino shieldContinue Open-Electronics.org is the brainchild of a world leader in hobby electronics Futura Group srl. Open-Electronics.org is devoted to support development, hacking and playing with electronics: we share exciting open projects and create amazing products! Open-Electronics.org is not just a container of ideas: it is also a web site lead by a team of engineers and geeks who will take part in the discussions and give support. Our mission is to become a reference Open Source hacking site with ideas and feedback aimed to enrich the community. © 2026 Open Electronics Futura Group Srl · Via Adige 11, 21013 Gallarate (VA), ItalyVAT no. IT10918280156 · Varese Companies Register no. 10918280156 · REA VA-297771 · Share capital €60,000 fully paid Terms of sale · Contact us We use cookies to count visits and to remember which page or campaign an order came from. No advertising or profiling cookies. You can change your mind at any time from the "Cookies" link at the bottom of every page. Details in our Cookie policy. Your consent ID:
Images (9): 


|
|||||
| Elekit Gyrostar Robot Kit | Japan Trend Shop | https://www.japantrendshop.com/elekit-g… | 10 | Sep 30, 2026 00:01 | active | |
Elekit Gyrostar Robot Kit | Japan Trend ShopURL: https://www.japantrendshop.com/elekit-gyrostar-robot-kit-p-7908.html Description: Elekit Gyrostar Robot Kit - Gyroscope are toys with a spinning wheel mechanism whose spin axis changes orientation by itself. Not only are they lots of fun, they bring learning to life by allowing you to see some of the laws of physics in spectacular action! The Elekit Gyrostar Robot Kit is one such toy that takes the gyroscop ... Content:
Gyroscope are toys with a spinning wheel mechanism whose spin axis changes orientation by itself. Not only are they lots of fun, they bring learning to life by allowing you to see some of the laws of physics in spectacular action! The Elekit Gyrostar Robot Kit is one such toy that takes the gyroscope concept to a whole new level by combining it with a robot, which you can make yourself using the pieces in the box. Other than a Philips screwdriver, pair of nippers, and two AA batteries to power it, the Elekit Gyrostar Robot Kit contains not only all the pieces for building the approximately 93 x 93 x 87 mm (3.7 x 3.7 x 3.4") gadget but also the many different types of rails/tracks it can move along. The kit has several modules that can be assembled in almost any number of ways to make your robot's movement more difficult – and more exciting. So teach your children, or yourself, some science while having a great time building and playing with this amazing robot! Specs and Features: Copyright © 2026 Japan Trend Shop
Images (10): 

|
|||||
| KAIST's AI robot breaks 100-meter world record - The Korea … | https://koreatimes.co.kr/www/tech/2023/… | 2 | Sep 30, 2026 00:01 | active | |
KAIST's AI robot breaks 100-meter world record - The Korea TimesURL: https://koreatimes.co.kr/www/tech/2023/12/133_365277.html Description: Korea Advanced Institute of Science and Technology (KAIST) says its artificial intelligence (AI) robot has broken the 100-meter world record for a... Content:
KAIST Hound runs a 100-meter sprint on an outdoor track at KAIST campus in Daejeon, Oct. 26. Courtesy of KAIST Prof. Park Hae-won from KAIST's Dynamic Robot Control and Design Laboratory Korea Advanced Institute of Science and Technology (KAIST) says its artificial intelligence (AI) robot has broken the 100-meter world record for a quadruped robot, citing Guinness World Records, Friday. KAIST Hound, developed by the school's Dynamic Robot Control and Design Laboratory, recorded a time of 19.87 seconds at the institute's outdoor track in Daejeon, Oct. 26. The robot made another record that could possibly become its second world record. Aiming to break the record in an indoor setting, Hound ran a treadmill and hit a maximum velocity of 6.5 meters per second. The figure beats Cheetah 2, developed by Massachusetts Institute of Technology, which recorded 6.4 seconds. Prof. Park Hae-won, who oversaw Hound's development, has applied to Guinness World Records for the indoor record. Hound developed the sprinting technique via reinforcement learning, a data-driven AI learning mechanism. Park's team programmed the self-learning system for Hound by inputting a maximum torque for its motor and a system for increasing velocity. The team also worked on the motor to distribute its output evenly through the robot's legs to achieve a balanced, symmetrical four-legged movement. Hound's legs were specially designed with light-weight materials to lighten its overall weight. "Hound has proven that Korea possesses globally undisputable technologies in robot hardware and robotic self-control AI," said Park, who specializes in the control and design of dynamic robot systems, legged locomotion robots and bio-inspired robots. The Agency for Defense Development, under the country's Defense Acquisition Program Administration, supported the research on Hound by granting a fund in 2019 for the development of new defense technologies.
Images (2): 

|
|||||
| Robot learns new skills by copying humans, then teaching itself | https://interestingengineering.com/ai-r… | 10 | Sep 30, 2026 00:01 | active | |
Robot learns new skills by copying humans, then teaching itselfURL: https://interestingengineering.com/ai-robotics/robot-learns-like-a-child-masters-tasks Description: New AI framework allows robots to imitate humans, improve through self-learning, and perform complex tasks with near-perfect reliability. Content:
Pick the engineering stories that matter and get them in your inbox. Access expert insights, exclusive content, and a deeper dive into engineering and innovation all with fewer ads or a completely ad-free experience. All Rights Reserved, IE Media, Inc. Follow Us On Access expert insights, exclusive content, and a deeper dive into engineering and innovation all with fewer ads or a completely ad-free experience. All Rights Reserved, IE Media, Inc. RL-100 first imitates human demonstrations, then uses reinforcement learning to autonomously improve its skills. A robot has learned to bowl, fold towels, unscrew lids, pour drinks, and prepare fresh orange juice by first imitating human demonstrations and then refining its skills through autonomous learning. Researchers developed a new training framework called RL-100 that combines imitation learning with reinforcement learning, enabling robots to perform a wide range of real-world manipulation tasks with high reliability. In tests, the system adapted to unfamiliar situations, recovered from disturbances, and even matched or outperformed human teleoperators in several tasks. The robot also operated continuously for seven hours serving fresh juice in a public mall without a single failure. Developed by researchers led by Shanghai Jiao Tong University, the framework, called RL-100, allows robots to first acquire safe, human-like behaviors from demonstrations and then improve those skills through autonomous trial-and-error. The approach overcomes one of robotics’ biggest challenges: moving beyond simply copying humans to achieving faster, more reliable, and more adaptable performance in unstructured environments. The researchers drew inspiration from how children learn. Babies initially rely on guidance from parents before gradually refining their abilities through independent practice. RL-100 follows the same philosophy through a three-stage learning pipeline. The first stage uses imitation learning, where the robot observes teleoperated demonstrations performed by human experts. These demonstrations train a diffusion-based visuomotor policy, enabling the robot to learn the relationship between visual inputs—captured through RGB cameras or 3D point clouds—and the corresponding manipulation actions. This stage provides a stable behavioral foundation but remains limited by the quality and efficiency of the human demonstrations. To overcome this “imitation ceiling,” the second stage introduces iterative offline reinforcement learning. Instead of relying solely on human data, the robot repeatedly performs tasks, stores the resulting experiences, and retrains itself using both demonstration data and its own successful attempts. A unified Proximal Policy Optimization (PPO)-based objective allows the system to refine the diffusion policy without destabilizing previously learned behaviors, while an offline policy evaluation mechanism prevents updates that could reduce performance. The final stage applies a smaller amount of online reinforcement learning directly on the physical robot. This phase specifically targets rare failure cases that remain after offline training, improving reliability from roughly 90 percent success to near-perfect task completion while requiring relatively little additional real-world data. RL-100 also addresses a key practical limitation of diffusion policies—their computational latency. Standard diffusion models require multiple denoising steps before producing each action, making them too slow for high-frequency robotic control. To solve this, the researchers developed a consistency-model distillation technique that compresses the multi-step diffusion policy into a single-step controller, reducing inference latency from around 100 milliseconds to about 10 milliseconds while maintaining performance. This enables faster reaction times and smoother control during deployment. The framework is designed to be task-, robot-, and representation-agnostic, supporting both single-arm and dual-arm robots, single-action and action-chunk control, and either RGB images or 3D point clouds without changing the underlying learning framework. Researchers evaluated RL-100 across eight challenging manipulation tasks involving rigid objects, deformable materials, liquids, and precision assembly. These included bowling, towel folding, pouring, unscrewing lids, folding boxes, and two stages of orange juicing. After completing the full training pipeline, the robot achieved a 100 percent success rate across 1,000 evaluation trials, matched or exceeded expert human teleoperators in task completion speed, adapted to unseen objects and environmental changes without retraining, and remained robust even when researchers physically interfered with its actions. In a real-world deployment, the robot continuously prepared fresh orange juice for customers in a shopping mall for seven hours without a single failure, demonstrating the framework’s potential for reliable long-term operation in homes, factories, and public spaces. Jijo is an automotive and business journalist based in India. Armed with a BA in History (Honors) from St. Stephen's College, Delhi University, and a PG diploma in Journalism from the Indian Institute of Mass Communication, Delhi, he has worked for news agencies, national newspapers, and automotive magazines. In his spare time, he likes to go off-roading, engage in political discourse, travel, and teach languages. Premium Follow
Images (10): 


|
|||||
| ICE plans to buy Boston Dynamics’ robot dogs | https://www.boston.com/news/local-news/… | 10 | Sep 29, 2026 16:00 | active | |
ICE plans to buy Boston Dynamics’ robot dogsURL: https://www.boston.com/news/local-news/2026/09/09/ice-plans-to-buy-boston-dynamics-robot-dogs/ Description: Boston Dynamics says ICE would have to follow the same terms and ethical rules as every other customer, including a ban on weaponizing them. Content:
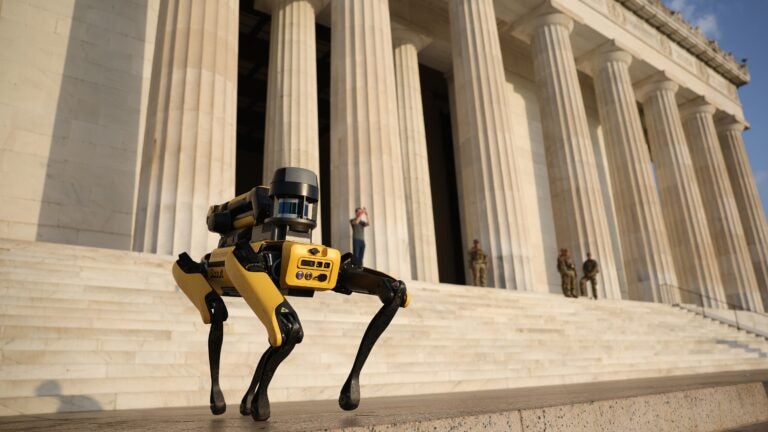
By Beth Treffeisen Send this article to your social connections. Send this article to your social connections. U.S. Immigration and Customs Enforcement (ICE) is trying to tap a local company for assistance. According to the U.S. Department of Homeland Security (DHS), ICE is planning to spend between $1 million and $2 million to to purchase Boston Dynamics’ Spot robots. The formal procurement process lists an expected solicitation start date of Sept. 4. However, the government has not yet issued an RFP for this. DHS said ICE wants to use the remotely operated robots to support public safety and law enforcement operations, including inspecting potentially dangerous areas, assessing hazards, and providing situational awareness without putting personnel at risk. The robots, DHS said, could help improve officer safety and decision-making in incidents involving dangerous, confined, unstable, or otherwise difficult-to-access areas. Boston Dynamics sells to many government agencies and public safety organizations. A company spokesperson said that the robots are used to keep people out of harm’s way and to help first responders in assessing dangerous situations. Examples include using Spot for hazardous gas detection, unexploded ordnance inspection, suspicious package investigation, search and rescue, subterranean or confined-space exploration, and structural assessments following fires, disasters, or other hazards. The company did not say how ICE would use the robots. Additionally, the company said that “any attempted weaponization of Boston Dynamics’ robots is strictly prohibited,” as outlined in its Terms and Conditions, ethical principles, and an open letter against weaponization. “We pledge that we will not weaponize our advanced-mobility general-purpose robots or the software we develop that enables advanced robotics, and we will not support others to do so,” the open letter said. “When possible, we will carefully review our customers’ intended application to avoid potential weaponization.” The open letter was led by Boston Dynamics and co-signed by five other leading robotics companies. Gov. Maura Healey did not respond to a request for comment on ICE’s plans to purchase the Boston Dynamics robots. Healey has previously previously opposed ICE operating in Massachusetts, including signing legislation in August aimed at restricting the federal agency’s activities in the state. At the same time, the Healey-Driscoll administration has backed Boston Dynamics and its expansion in Massachusetts, awarding the company $25 million to support its recently announced Waltham expansion. “Boston Dynamics has played a central role in defining the global robotics industry from right here in our state, and it’s why we wanted them to choose Massachusetts as the site of their expansion,” Healey said in a statement at the time. Beth Treffeisen is a general assignment reporter for Boston.com, focusing on local news, crime, and business in the New England region. Get everything you need to know to start your day, delivered right to your inbox every morning. SIGN UP ©2026 Boston Globe Media Partners, LLC Stay up to date with everything Boston. Receive the latest news and breaking updates, straight from our newsroom to your inbox.
Images (10): 

|
|||||
| Technical SEO for LLM Scrapers: Crawl, Chunk, and Citation Readiness … | https://www.singlegrain.com/blog-posts/… | 10 | Sep 29, 2026 00:01 | active | |
Technical SEO for LLM Scrapers: Crawl, Chunk, and Citation Readiness Checklist - Single GrainURL: https://www.singlegrain.com/blog-posts/technical-seo-for-llm-scrapers/ Description: Make sure LLM scrapers can crawl, chunk, and cite your pages with access, extractable answers, and retained sources. Content:
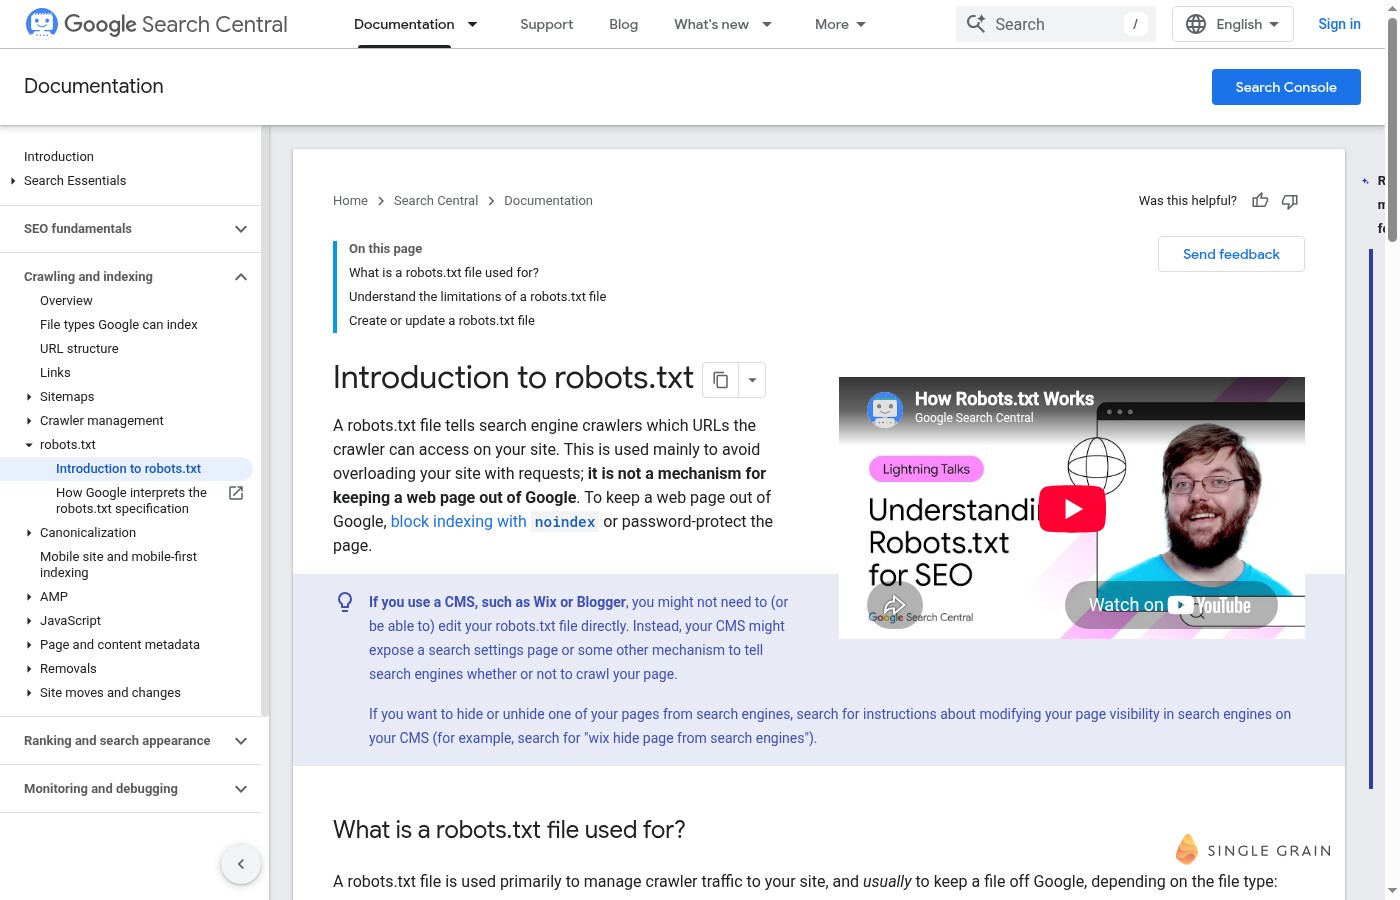
AI SEO that plans, writes & ranks - 90+ hours/month saved Personalized LinkedIn ads in minutes, not weeks. 40% higher B2B conversions. LLM scraper readiness starts with access, extractable answers, and claims that retain their sources when separated from the page. The deliverable is a reusable checklist tied to URLs, evidence, and owners. It does not predict citations or assign an LLM visibility score. Buy implementation help when these controls cross SEO, engineering, and content responsibilities without a clear operator. At a pre-release review, a technical SEO opens a money page’s robots rules beside its rendered preview. The preview contains the offer and its supporting evidence. The crawler-specific rule blocks the URL. This worked example starts with a concrete artifact: a page that looks ready to a buyer but is unavailable to the intended crawler. In the same review, a content engineer compares the response HTML with the browser DOM. Navigation links arrive immediately; the answer block appears only after JavaScript runs. The checklist has no answer selector or chunk boundary. These are illustrative implementation failures, not Single Grain client results. Both require a page-level fix before another model purchase. Job delta: Closest live technical SEO checklists target Googlebot. This page adds crawl→chunk→cite-ready controls for LLM scrapers, with pass/fail evidence per URL. Kill rule: any Fail without owner+fix ticket → block “AI-ready” claim on that URL. Operator artifact : LLM scraper readiness checklist (illustrative ACME row; not a client result). Eng+content blocks “AI-ready” claims until Pass/Fail is evidenced: Open Future Forum (2026-09-06) puts 81% of 230 leaders past exploring agentic AI, so fix crawler access and extractable answer blocks before buying another model. Eric’s Jev as the fast cheap middle layer: classify, apply criteria, route between models and ops changes where control sits before the next expensive write. The same review applies Reusable workflows beat custom premium work; build them, then hand them to the team, so uncertain rows route to a human instead of auto-publishing. Together with the embedded scene above, that is three on-angle Eric tape inputs for this job, not a link dump. A visibility report records whether a sampled answer mentions your brand. Crawl readiness asks whether a particular agent can retrieve a particular URL and extract a useful, attributable passage. A mention cannot prove that your current pricing page is accessible. An accessible pricing page cannot guarantee a mention. Single Grain’s LLMO best-practices guide covers the broader optimization program. This checklist addresses the implementation handoff underneath it: access rules, canonical targets, answer selectors, chunk boundaries, and source-bearing claims. It produces repair tickets, not another visibility dashboard. Google’s guidance for AI features in Search points publishers toward existing SEO foundations rather than special AI markup. That supports the recommendation in Single Grain’s AI search optimization is SEO: repair the discovery and content layer before commissioning a parallel “GEO-only” stack. Google’s requirements apply to Google; other crawlers still need their own access tests. The Open Future Forum September 2026 report reports that 81% of 230 marketing and growth leaders were past exploring agentic AI. Attribution was the leading named challenge, appearing in 20 of 96 open answers. Those are different denominators, and neither measures scraper readiness. They support an operational purchase decision: require evidence trails alongside automation. In Eric’s September video, “A better model still needs a better workflow,” the discussion moves from model improvement to the workflow that makes the model useful. Applied to this page review, the sequence is concrete: inspect the fetch, locate the answer block, then repair the extraction contract. The scraper-specific example is our application of that lesson, not a claimed demonstration from the video. The engineer fetches the example service URL and finds a header, navigation menu, and application shell. The browser eventually displays the answer, but the tested non-rendering fetch does not. Asking a stronger model to summarize that response gives it more capability without supplying the missing text. Assign the fix to content engineering: deliver the essential answer in server-rendered or static HTML, give it a stable selector such as the explicit input contracts used for reliable marketing bots, and separate sections with meaningful headings. A selector such as #service-answer is a local extraction contract, not a universal crawler standard. The acceptance test is whether the chosen fetch method returns the answer and its qualifications together. Do not buy a stronger model to conceal missing schema or controls. First supply a stable content structure and an extraction test. Add relevant structured data only when it accurately describes visible content. No markup can substitute for an answer absent from the retrieved page. The technical SEO now checks the blocked money page from the opening review. The input bundle contains the URL, intended user agent, robots file, response headers, canonical element, and retrieved HTML. The checklist records which rule blocks access rather than collapsing every crawler into one permission. Google’s robots.txt documentation describes crawler access controls and their limitations. Robots rules are not authentication, and blocking crawling does not reliably remove a URL from search results. Keep private content behind access controls. For public content, distinguish crawl permission from indexing and snippet directives, and check the relevant crawler’s documentation. The filled artifact below uses illustrative URLs and proposed content. “Pass” means the stated local check succeeds, not that an LLM will cite the page. The proposed service claim must match the actual offer before it becomes production copy. LLM Scraper Readiness Checklist Canonicalization identifies the preferred URL; it does not compel a model’s citation choice. A useful chunk contains the claim, its scope, and supporting evidence without borrowing essential context from a distant accordion. For numerical claims, retain units, dates, denominators, and source links inside the same logical section. Run the checklist as a bounded job with a defined URL set and saved fetch evidence. Eric’s Jev middle-layer discussion recommends inexpensive classification, criteria checks, and routing. Apply that before drafting: classify each failure as access, extraction, evidence, or ownership, then send it to the responsible owner. Keep the human ship gate here. Eric’s early Jev work tests support routing uncertain classifications to review rather than automatic action. Name the technical SEO lead as approver for crawl changes and the content engineering lead for extraction changes; do not auto-publish either from a classifier’s output. Eric’s reusable-workflow recommendation changes the deliverable: build a job card the team can rerun after template changes, rather than commissioning a fresh premium audit each time. His decision-layer discussion adds a constraint: label thin evidence thin, and use misclassifications to improve checks before expanding automation. Single Brain is the AI implementation OS for job-specific agents, evaluation, and kill switches. Scope this installation around the checklist: a URL queue, saved fetches, deterministic access checks, extraction tests, evidence routing, and a stop control for unexpected behavior. The operator view should expose the retrieved passage and failure reason, not just a green status. Keep the work manual when permissions are unresolved, the page set changes rarely, or the business cannot define acceptable evidence. Automate repeatable checks once the inputs and acceptance criteria are stable. A stronger model remains the wrong purchase when the answer block, schema, or control layer is missing. Hire Single Grain to install and run the system when you need SEO, engineering, and content operations without staffing that coordination internally. Bring your money-page URLs, crawler policy, and representative templates to a Single Grain consultation. Scope the engagement around repaired retrieval paths and reusable operating jobs, with citation outcomes evaluated separately. Eric Siu is a seasoned entrepreneur and CEO of the digital marketing agency Single Grain, which drives scalable and predictable revenue growth using paid ads, SEO, and content marketing. He has successfully scaled multiple businesses and assisted clients in various industries, including Amazon, Uber, and Salesforce, to do the same. Eric hosts two podcasts: Marketing School with Neil Patel and Leveling Up, where he dissects growth levers that help businesses scale. Follow him on Twitter @ericosiu. Our newsletter is brimming with marketing strategies that are working right now and must-have resources. Join our community of 15,000+ subscribers, including professionals from Amazon, Google, and Samsung. Join 15,000+ marketers getting proven strategies Single Grain is a full-service digital marketing agency that helps great companies grow their revenues online. Get in touch: contact@singlegrain.com © 2026 Single Grain. All rights reserved. Sitemap | Privacy Policy | Personal Data Removal Request | Notice of Non-Affiliation | Accessibility Get Free Instant Access 8 Effective Online Marketing Tactics That Have Generated 1,545%+ ROI for our Customers (and You Can Easily Use) We hate SPAM and promise to keep your email address safe. Personal attention guaranteed You'll hear back from me or one of our senior strategists directly. "Single Grain was instrumental to our growth. They're especially ahead of the game with AI." — Yaniv Masjedi, Co-Founder & CMO, Nextiva Trusted by teams at Amazon, Uber, Salesforce, and Airbnb ClickFlow’s AI plans and writes production-grade content — so you don’t need 10 more writers and editors. Early adopters average 27% more organic traffic in 6 months. Karrot generates personalized ads and landing pages for every target account in minutes, not weeks. One team closed 2 deals from just 15 accounts in under 2 weeks.
Images (10): 


|
|||||
| Digit 5, l'umanoide Agility che lavora senza recinzioni | https://www.tecnoandroid.it/news/digit-… | 10 | Sep 26, 2026 16:00 | active | |
Digit 5, l'umanoide Agility che lavora senza recinzioniURL: https://www.tecnoandroid.it/news/digit-5-lumanoide-agility-che-lavora-senza-recinzioni-1977558/ Description: Il robot Digit 5 di Agility Robotics ha superato una valutazione indipendente OSHA e può lavorare accanto agli operai senza barriere. Content:
Con Digit 5 Agility Robotics prova a fare il salto che l’intera industria degli umanoidi aspetta da anni, cioè togliere le barriere fisiche che finora tenevano i robot separati dagli operai. L’azienda, fondata nel 2015 a Salem, in Oregon, sviluppa la famiglia Digit da diverse generazioni e sostiene che i modelli precedenti abbiano accumulato oltre 65.000 ore di lavoro effettivo presso clienti del calibro di GXO, Schaeffler, Amazon e Toyota Motor Manufacturing Canada. Tre anni di uso quotidiano del Digit 4 hanno prodotto una quantità di feedback che ora si ritrova, tradotta in hardware e software, nella nuova versione. Peggy Johnson, amministratrice delegata di Agility Robotics, la mette in termini piuttosto diretti, parlando della rimozione di un ostacolo fondamentale alla diffusione su larga scala degli umanoidi industriali. Il punto, insomma, non è tanto la forza bruta quanto la possibilità di lavorare accanto alle persone senza recinzioni. TecnoAndroid · su Google Seguici su Google e non perdere nulla Aggiungi TecnoAndroid alle tue fonti preferite su Discover e segui il nostro profilo Google: le notizie tech più importanti arrivano direttamente sul tuo telefono. L’architettura di sicurezza di Digit 5 si appoggia a tre dispositivi che lavorano insieme. Il robot combina algoritmi proprietari con una serie di sensori per capire se c’è qualcuno nei paraggi, poi decide da sé come comportarsi, scansando la persona, fermandosi oppure mettendosi a sedere. A questo si aggiungono segnali visivi e sonori che comunicano in anticipo l’intenzione di muoversi, mentre un controllore di sicurezza indipendente scatta nel momento in cui la distanza diventa pericolosa. Secondo l’azienda, Digit 5 è il primo robot umanoide a superare su una linea di produzione reale, quella di un cliente, una valutazione indipendente allineata agli standard di sicurezza industriale dell’Occupational Safety and Health Administration statunitense. C’è anche il capitolo NVIDIA: Agility Robotics è il primo partner di lancio di Halos for Robotics, la piattaforma di sicurezza appena presentata dal colosso dei chip, basata sull’infrastruttura IGX Thor e su Halos Core. Deepu Talla, vicepresidente della robotica e dell’AI embedded di NVIDIA, ha spiegato che la capacità di operare in totale sicurezza vicino a persone e beni è la condizione necessaria per passare dai prototipi ai dispiegamenti industriali veri. L’azienda dell’Oregon partecipa inoltre alla stesura degli standard ANSI/A3 TR R15.108 e ISO 25785 uno, ancora in elaborazione, dedicati ai robot mobili industriali e agli umanoidi. Sul fronte delle prestazioni i numeri sono concreti. Le gambe di Digit 5 sono progettate per sopportare sollevamenti ripetuti e il robot arriva a 22,7 kg, cioè il 40% in più rispetto a Digit 4. In un impianto che segue le regole OSHA, questo significa poter coprire da solo operazioni di sollevamento finora assegnate a un lavoratore umano. Cambia anche la batteria: 90 minuti di lavoro con una ricarica di nove minuti, quindi un rapporto tra autonomia e ricarica di dieci a uno, contro il due a uno della generazione precedente. Nella pratica il robot può restare operativo per più di venti ore su ventiquattro. Il perimetro dei compiti si allarga parecchio. Digit 4 si occupava soprattutto di movimentare contenitori, mentre Digit 5 è pensato per coprire a regime l’intero flusso di un impianto, dalla depallettizzazione della merce in arrivo all’alimentazione delle macchine, passando per confezionamento, sequenziamento e controllo qualità, fino alla pallettizzazione prima della spedizione. Grazie alla piattaforma Agility Arc, ogni trasferimento viene coordinato con robot mobili autonomi, nastri trasportatori e sistemi di gestione dello stabilimento, con monitoraggio di disponibilità, produttività e tempo medio tra gli incidenti. Un dato dal campo: nel sito GXO di Flowery Branch, Digit 4 ha superato i 100.000 sacchi movimentati con una precisione attorno al 98%. L’assemblaggio avviene a RoboFab, la fabbrica di Agility Robotics a Salem. Sono 6.500 metri quadrati che, a pieno regime, dovrebbero sfornare fino a 10.000 robot Digit all’anno, con un organico previsto superiore alle 500 persone. La novità geografica riguarda il mercato: per la prima volta Digit verrà venduto fuori da Stati Uniti e Canada, partendo da Unione europea e Regno Unito, dove però il modello deve ancora ottenere la certificazione CE e le altre omologazioni necessarie. L’accesso anticipato è atteso nel primo semestre del 2027, con la disponibilità generale annunciata per la fine del 2027 presso gli operatori di produzione, stoccaggio e distribuzione. Fonte: TecnoAndroid Notizie, recensioni e approfondimenti di tecnologia, scienza e innovazione. Non solo Android. Ultimo aggiornamento: 2026-09-26 17:50:00 2012 – 2026 © Tecnoandroid.it – Gestito dalla STARGATE SRLS – P.Iva: 15525681001 Testata telematica quotidiana registrata al Tribunale di Roma CON DECRETO N° 225/2015, editore STARGATE SRLS. Tutti i marchi riportati appartengono ai legittimi proprietari. Questo articolo potrebbe includere collegamenti affiliati: eventuali acquisti o ordini realizzati attraverso questi link contribuiranno a fornire una commissione al nostro sito. Non perderti nemmeno un’offerta Smartphone, notebook, gadget tech al prezzo più basso.
Images (10): 



|
|||||
| Toyota plans to deploy 400,000 factory robots from 2028 | … | https://www.automotiveworld.com/news/to… | 4 | Sep 26, 2026 00:01 | active | |
Toyota plans to deploy 400,000 factory robots from 2028 | Automotive WorldURL: https://www.automotiveworld.com/news/toyota-plans-to-deploy-400000-factory-robots-from-2028/ Description: Having robots learn by watching workers lets Toyota generate training data organically rather than depend on simulation. By Stewart Burnett Content:
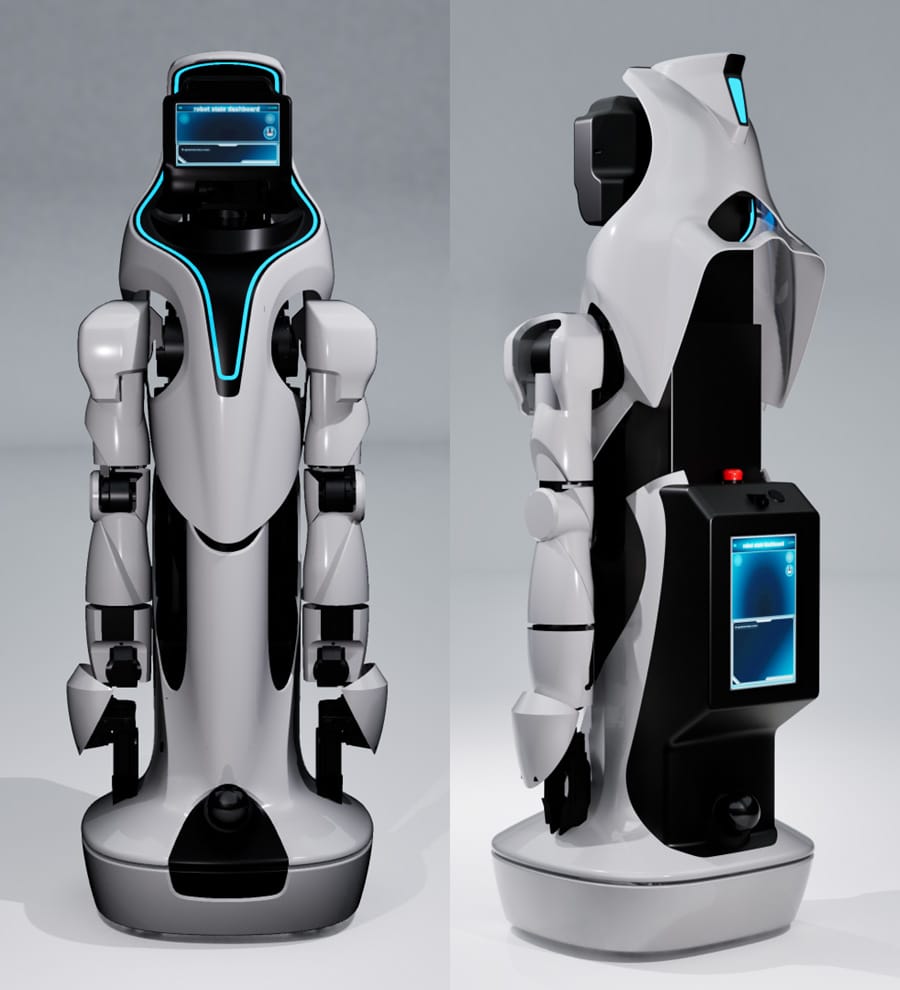
Don't have an account? Subscribe “Our goal is to help stakeholders understand the future of mobility.” Home › News › Toyota plans to deploy 400,000 factory robots from 2028 Having robots learn by watching workers lets Toyota generate training data organically rather than depend on simulation. By Stewart Burnett Toyota estimates it could spend as much as JP¥1tn (US$6.4bn) annually from 2028 automating its global factories, deploying roughly 400,000 robots at both its own plants and those of major suppliers. The automaker has told investors that the figure covers both humanoid and non-humanoid machines, including replacements for existing equipment, although it neither confirmed the investment would definitely proceed nor how many years it might continue. Of the total, Toyota plans to deploy 150,000 robots at its own plants and 250,000 across group company facilities. The flagship humanoid, named Eley, weighs 50 kg, uses two-fingered hands rather than a full humanoid grip, and moves on wheels powered by battery or cord instead of walking. This is a deliberate trade-off toward proven reliability over the bipedal approach rivals like Tesla and Figure are pursuing for their own factory robots. Eley learns by observing Toyota’s own workers rather than relying primarily on external datasets or simulation: employees wear finger-shaped jigs modelled on the robot’s hands while repeating routine tasks, letting Eley learn its technique directly from demonstration. At a technology briefing at Toyota’s European headquarters earlier in September, the robot folded T-shirts with near-perfect accuracy after 1,500 practice sessions over two weeks. Toyota eventually plans to share centrally learned data across its factories worldwide, so robots in different countries can acquire the same skills without repeating the training process locally. However, this rollout leans on infrastructure Toyota has built over decades, and may therefore be outdated, rather than starting from a blank slate. As it stands, the group operates 60 factories globally and employs 18,000 veteran “takumi” workers, whose expertise it intends to capture as training data, and plans call for robots to help train new human employees as well as learn from existing ones. “We aim for a world where robots coexist with humans, rather than replacing them,” said Executive Vice President Hiroki Nakajima in a statement. Critics might argue that the operative word there is “aim”. While not catching the headlines of Tesla’s Optimus or Hyundai’s Atlas humanoid robots, Toyota’s presence in this segment is nothing new. Indeed, it stretches back more than two decades, from the Human Support Robot developed for elder care to the Welwalk rehabilitation exoskeleton and the teleoperated T-HR3 humanoid. More recently, however, it has shifted towards Large Behavior Models developed through the Toyota Research Institute, which use diffusion-based generative AI to teach robots physical skills, such as pouring liquid or using a tool, from just a few minutes of human demonstration rather than manually coded instructions. The automaker has separately partnered with Agility Robotics to deploy bipedal Digit humanoids for tote handling and logistics tasks at sites including Toyota Motor Manufacturing Canada. Toyota’s wheeled, multi-form-factor approach sits apart from rivals converging on a single bipedal design, and the distinction matters most in how each company is choosing to compete. Hyundai’s Boston Dynamics-built Atlas, due at its Georgia plant from 2028, and Tesla’s Optimus both bet on human-like mobility as the eventual differentiator. Meanwhile, Toyota is betting instead that a robot’s ability to learn fine manual skills quickly, on wheels, from watching its own workforce, matters more for near-term factory deployment. September 25, 2026 September 25, 2026 September 25, 2026 Let us help you understand the future of mobility "*" indicates required fields Your essential guide to the automotive industry developments that matter. News every Monday. Analysis every Thursday. Δ August 7, 2025 Q2 2026 was one of the industry's best periods in years, yet there's a disconnect between revenue, profit and volume. July 31, 2026 Automotive World's monthly snapshot of past and future sales LV volumes broken down by region. July 24, 2026 Automotive World forecasts production output for Mitsubishi during the period to 2030. Welcome back , to continue browsing the site, please click here
Images (4): 


|
|||||
| Unitree humanoid robots return to America’s Got Talent for Chinese … | https://interestingengineering.com/ai-r… | 10 | Sep 25, 2026 08:00 | active | |
Unitree humanoid robots return to America’s Got Talent for Chinese dance finaleDescription: Chinese dancer Wu Yufei performs traditional shuixiu water-sleeve routine with 8 Unitree humanoid robots in the America’s Got Talent finale. Content:
Pick the engineering stories that matter and get them in your inbox. Access expert insights, exclusive content, and a deeper dive into engineering and innovation all with fewer ads or a completely ad-free experience. All Rights Reserved, IE Media, Inc. Follow Us On Access expert insights, exclusive content, and a deeper dive into engineering and innovation all with fewer ads or a completely ad-free experience. All Rights Reserved, IE Media, Inc. Chinese dancer Wu Yufei and eight Unitree humanoids have taken traditional Chinese dance to one of America’s biggest television stages. A Chinese dancer and eight humanoid robots from Unitree Robotics have brought a centuries-old Chinese dance tradition to the stage of America’s Got Talent, performing a synchronized shuixiu, or “water-sleeve,” routine during the Season 21 finale. The performance by 27-year-old Sichuan dancer Wu Yufei and the Unitree G1 robots combined traditional Chinese movement with humanoid robotics, giving American television audiences an unusual meeting of classical performance and modern machines. The group had already become one of the season’s most recognizable technology-focused acts before reaching the finale. Wu and eight Unitree G1 humanoids first appeared on America’s Got Talent during the June 2 auditions. Their tightly synchronized routine included dance, martial-arts movements and coordinated backflips, earning all four judges’ approval and sending the act through to the next stage. The robots returned during the competition before advancing to the September 22 finale. Reporting from Chinese media described the latest performance as a water-sleeve dance, incorporating the long, flowing sleeves associated with Chinese traditional theater and dance. The act performed under the name Homies, with Wu serving as the human dancer alongside the robot performers. Chinese reporting said Unitree chief marketing officer Wang Qixin described the group as the first Chinese team to reach the America’s Got Talent finale. The finale performance also builds on a longer effort to make humanoid robots capable of performing complicated choreography alongside humans. Getting a humanoid robot to reproduce a dance routine requires considerably more than simply telling it to imitate a human. According to reporting by AFP, the process involves capturing detailed human movements, simulating them on computers and transferring the resulting motion data to the robots. Engineers then have to fine-tune the movements so the machines can execute the choreography reliably. That creates a particular challenge for dance. Robots can be highly consistent once a sequence has been programmed, but they have difficulty with movements requiring the flexibility of a human body. They also generally cannot improvise or adjust to unexpected changes in music the way a human dancer can. For the Unitree performance, however, that repeatability is an advantage. Eight robots can be programmed with the same movements and execute them in synchronization, allowing choreography that would otherwise require considerable coordination between individual performers. Wu told AFP that after months of training with the robots, they began to feel less like machines and more like members of a team. The G1 is Unitree’s humanoid robot platform and has become increasingly visible outside conventional robotics demonstrations. The machines have been shown performing complex movements including walking, balancing, martial arts and backflips. Unitree robots also gained widespread attention in China after appearing in the country’s annual Spring Festival Gala, where humanoid machines performed alongside human dancers. That exposure helped fuel a wider trend of robot performances at commercial events and public shows. For the robotics industry, performances such as the America’s Got Talent routine serve a purpose beyond entertainment. They provide a highly visible demonstration of balance, motion control, multi-robot coordination and the ability to repeatedly execute complex sequences in a public environment. At the same time, the performance highlights the current limits of humanoid robotics. The choreography remains heavily scripted, with humans and engineers playing a central role in designing and refining the movements. Still, putting eight humanoid robots alongside a human dancer and having them perform a traditional Chinese dance on one of America’s biggest talent shows offers a striking demonstration of how rapidly robotics is moving from laboratories and demonstrations into mainstream entertainment. Kaif Shaikh is a journalist and writer passionate about turning complex information into clear, impactful stories. His writing covers technology, sustainability, geopolitics, and occasionally fiction. A graduate in Journalism and Mass Communication, his work has appeared in the Times of India and beyond. After a near-fatal experience, Kaif began seeing both stories and silences differently. Outside work, he juggles far too many projects and passions, but always makes time to read, reflect, and hold onto the thread of wonder. Premium Follow
Images (10):
|
|||||
| Figure AI humanoids sort 28,000 packages in 24-hour autonomous test | https://interestingengineering.com/ai-r… | 10 | Sep 24, 2026 16:00 | active | |
Figure AI humanoids sort 28,000 packages in 24-hour autonomous testURL: https://interestingengineering.com/ai-robotics/figure-ai-humanoids-24-hour-autonomous-run Description: Figure AI says its humanoid robots completed over 24 hours of nonstop autonomous work using Helix-02 AI. Content:
Pick the engineering stories that matter and get them in your inbox. Access expert insights, exclusive content, and a deeper dive into engineering and innovation all with fewer ads or a completely ad-free experience. All Rights Reserved, IE Media, Inc. Follow Us On Access expert insights, exclusive content, and a deeper dive into engineering and innovation all with fewer ads or a completely ad-free experience. All Rights Reserved, IE Media, Inc. Figure AI claims its humanoid robots crossed 24 hours of nonstop autonomous package sorting without failures. Figure AI says its humanoid robots have now crossed 24 hours of continuous autonomous work, extending what was initially planned as an eight-hour test into a nonstop multi-day operation. The California-based robotics startup said three humanoid robots running its Helix-02 AI system are autonomously sorting small packages around the clock without human control. The company livestreamed the operation online, where the robots were nicknamed Bob, Frank, and Gary by viewers. “Our original goal was an 8-hour run. After zero failures yesterday, we decided to keep going. We’re now over 24 hours of continuous autonomous operation without a failure. This is uncharted territory,” Brett Adcock, founder and CEO of Figure AI, wrote on X. The company said the robots have already sorted more than 28,000 packages during the ongoing operation while maintaining speeds close to human workers. Day 2 is Live: Watch humanoid robots Bob, Frank, and Gary running 24/7. This is fully autonomous running Helix-02 https://t.co/zaRVkoLa4e The livestream has drawn significant online attention, with viewers continuously tracking the robots’ uptime and performance as the operation moved beyond its original eight-hour target. Figure AI also added visible name tags to the robots after commenters began referring to them as Bob, Frank, and Gary. According to Figure AI, the robots detect barcodes, pick up packages, and place them barcode face-down onto conveyor belts using onboard cameras and AI reasoning. “Humans average around 3 seconds per package. F.03 is now around human parity. The robots are reasoning directly from camera pixels,” Adcock said. Frank merch in the house!!p.s. robots are closing in on 30 hours of nonstop operations. Hopefully they don't fail and keep going pic.twitter.com/LXExFik5bo The company added that the humanoids are operating fully autonomously using Helix-02, its in-house neural network running entirely onboard the robots. Figure AI stressed there is no teleoperation involved in the process. “There is no teleoperation – every action comes directly from Helix-02,” Adcock wrote. The system also includes automatic recovery mechanisms. Figure AI said if a robot gets stuck or encounters an unfamiliar situation, the AI system can trigger an autonomous reset and resume work without human intervention. “If the robot gets stuck or the AI policy goes out of distribution, Helix triggers an automatic reset,” Adcock said. Figure AI further claimed the robots can independently leave the work floor for maintenance if software or hardware issues appear, while another robot automatically takes over operations to maintain uptime. “If a robot has a software or hardware issue, it autonomously leaves for maintenance and another robot takes over,” Adcock wrote. The latest demonstration builds on Figure AI’s earlier claims that its humanoid robots completed full eight-hour shifts autonomously using Helix-02. The company has also previously tested humanoid robots at BMW manufacturing facilities in South Carolina. Helix-02 is designed as a unified neural network combining vision, touch sensing, proprioception, and whole-body control. Unlike conventional industrial robots that separate movement and manipulation systems, Figure AI says its robots use a single AI model to handle walking, balancing, object handling, and coordination in dynamic environments. The company is competing with firms including Tesla, Agility Robotics, and Apptronik to commercialize humanoid robots for warehouse, factory, and logistics operations. With over a decade-long career in journalism, Neetika Walter has worked with The Economic Times, ANI, and Hindustan Times, covering politics, business, technology, and the clean energy sector. Passionate about contemporary culture, books, poetry, and storytelling, she brings depth and insight to her writing. When she isn’t chasing stories, she’s likely lost in a book or enjoying the company of her dogs. Premium Follow
Images (10):
|
|||||
| Figure, accordo con Nscale per 100.000 GPU e robot umanoidi … | https://www.tecnoandroid.it/news/figure… | 10 | Sep 24, 2026 16:00 | active | |
Figure, accordo con Nscale per 100.000 GPU e robot umanoidi - TecnoAndroidDescription: Un'intesa con Nscale porta fino a 100.000 GPU NVIDIA all'addestramento dei Figure robot umanoidi, con primo dispiegamento in Texas nel 2027. Content:
Un accordo destinato a spostare gli equilibri nella robotica: Figure, tra le realtà più osservate del settore negli Stati Uniti, si è assicurata una capacità di calcolo enorme per addestrare i modelli di intelligenza artificiale che governeranno i suoi robot umanoidi di prossima generazione. Non un aggiornamento marginale, ma la costruzione di quella che si annuncia come una delle infrastrutture di calcolo più grandi mai dedicate all’intelligenza artificiale applicata al mondo fisico. Il numero che colpisce è chiaro e difficile da ignorare: fino a 100.000 GPU. La partnership è stata siglata con la britannica Nscale, e prevede l’utilizzo della futura piattaforma NVIDIA Vera Rubin. Il primo dispiegamento è programmato per la seconda metà del 2027, con base in Texas. Una tempistica che dice molto sulla natura del progetto, perché parlare di un’infrastruttura di queste dimensioni significa ragionare su anni, non su mesi, e significa mettere in fila fornitori, energia, spazi fisici e software. TecnoAndroid · su Google Seguici su Google e non perdere nulla Aggiungi TecnoAndroid alle tue fonti preferite su Discover e segui il nostro profilo Google: le notizie tech più importanti arrivano direttamente sul tuo telefono. La domanda sorge spontanea per chi non frequenta il settore ogni giorno. Un umanoide non ha bisogno soltanto di motori e sensori, ha bisogno di capire cosa sta guardando e decidere cosa fare. È qui che entra in gioco Helix, il sistema di intelligenza artificiale sviluppato da Figure che permette ai suoi robot di interpretare le immagini raccolte e tradurle in movimenti concreti, in azioni utili. Prendere un oggetto, spostarlo, riconoscere una situazione mai vista prima e reagire senza istruzioni scritte riga per riga. Il punto è che un sistema di questo tipo migliora soltanto se gli vengono mostrati esempi. Molti esempi. E crescenti. Non simulazioni astratte, ma situazioni tratte dal mondo reale, con tutte le sue imperfezioni, le luci sbagliate, gli oggetti fuori posto, le variabili che nessun laboratorio riesce a prevedere completamente. Ogni volta che la quantità di dati aumenta, aumenta anche la potenza di calcolo necessaria per digerirli e trasformarli in comportamenti affidabili. Ecco spiegato il motivo di una corsa alle GPU che, vista da fuori, potrebbe sembrare sproporzionata. Quello che sta emergendo è una differenza sostanziale rispetto all’intelligenza artificiale a cui il pubblico si è abituato negli ultimi anni. I modelli che generano testo o immagini lavorano dentro uno schermo, dove un errore si corregge con un clic. La AI fisica invece agisce nello spazio, tra persone e oggetti reali, e un errore ha conseguenze immediate. Questo alza l’asticella in modo netto, sia sulla qualità dei dati sia sulla mole di addestramento richiesta. Figure ha scelto di affrontare il problema alla radice, costruendo la propria capacità di calcolo su misura invece di dipendere soltanto da risorse condivise. Una strategia impegnativa dal punto di vista industriale, che però risponde a una logica semplice: chi controlla l’infrastruttura controlla i tempi di sviluppo. E in un settore dove la competizione si misura in mesi di vantaggio, il fattore tempo pesa quanto la tecnologia. Il calendario, per ora, resta quello annunciato. Le prime GPU basate su NVIDIA Vera Rubin arriveranno nella seconda metà del 2027 sul suolo texano, dando forma concreta a un progetto che punta a rendere i robot umanoidi di Figure più autonomi e più capaci di operare in ambienti non preparati appositamente per loro. Nel frattempo lo sviluppo di Helix continua, alimentato dagli esempi raccolti sul campo, perché senza quel materiale nessuna quantità di silicio produrrebbe risultati. Fonte: TecnoAndroid Notizie, recensioni e approfondimenti di tecnologia, scienza e innovazione. Non solo Android. Ultimo aggiornamento: 2026-09-24 17:50:00 2012 – 2026 © Tecnoandroid.it – Gestito dalla STARGATE SRLS – P.Iva: 15525681001 Testata telematica quotidiana registrata al Tribunale di Roma CON DECRETO N° 225/2015, editore STARGATE SRLS. Tutti i marchi riportati appartengono ai legittimi proprietari. Questo articolo potrebbe includere collegamenti affiliati: eventuali acquisti o ordini realizzati attraverso questi link contribuiranno a fornire una commissione al nostro sito. Non perderti nemmeno un’offerta Smartphone, notebook, gadget tech al prezzo più basso.
Images (10):

|
|||||
| China is exploring humanoid robots for war – but what … | https://theconversation.com/china-is-ex… | 6 | Sep 23, 2026 00:03 | active | |
China is exploring humanoid robots for war – but what role could they play?Description: The People’s Liberation Army called for researchers to accelerate progress on building humanoid robots designed for military uses. Content:
Share article Print article At the World Humanoid Robot Games in Beijing, a humanoid robot named Tiangong Ultra ran the 100-metre sprint in a staggering 8.64 seconds, shattering Jamaican sprinter Usain Bolt’s legendary human world record of 9.58 seconds. The internet laughed at the robots’ awkward, lurching finishes and spectacular falls – but the laughter masked a chilling reality. Just two days after the games concluded the official newspaper of China’s People’s Liberation Army (PLA) called for researchers to accelerate moving these cutting-edge machines from the laboratory to military training grounds. They referred to them not as experiments, but as “combatants”. As a robotics researcher myself, working daily with robot simulation, reinforcement learning, and the foundational software and simulation tools that power them (such as ROS 2 and Gazebo), I watch these developments with a mix of awe and deep concern. The public often views humanoid robots as clunky sci-fi novelties. The reality is far different: the hardware is already highly capable, and the software is advancing at an unprecedented pace. But the real story is not just that a robot can beat a human on a running track. It’s what that performance reveals: China’s ability to integrate motors, reducers (gears used in precise joint movement), sensors, control software, testing infrastructure and manufacturing capacity into one unified industrial system. A sprinting humanoid is not just a stunt. At high speeds, every foot strike creates violent ground reaction forces. Balance corrections must happen in milliseconds, as a single small error can send the machine crashing into the barrier. For decades, the physical mechanics of humanoid robots, including the actuators (a component, such as a motor, that converts energy into physical movement), sensors, and the sheer physics of bipedal balance, were the main hurdles. Today, those mechanical problems are largely solved. Carbon fibre and aluminium bodies keep mass and inertia (how a robot’s mass resists change) low. Advancements in actuator technology deliver torque capacities of up to 400Nm (Newton-metres – a unit of torque, or twisting force) in humanoid joints, providing the ultimate combination of power and agility. What you saw on the track in Beijing was not just a triumph of motors, but a triumph of coding. A real breakthrough is happening in software. Robots are trained in virtual simulation environments, running millions of trial-and-error scenarios through reinforcement learning before the robot ever takes a physical step. Reinforcement learning is an area of artificial intelligence (AI) where robots make decisions based on the results of their actions. This allows them to learn how to recover from trips, adjust to uneven ground, and process chaotic environments in real time. Humanoid robots are rapidly bridging the gap between controlled laboratory conditions and the unpredictable real world. But all this leads to an inevitable question: why would a military want a complex, expensive humanoid when they could use vastly cheaper, rugged, tracked or wheeled drones? In open-field combat, tracked vehicles are absolutely superior. They heave bigger payloads, carry thick ballistic armour, and are far more energy efficient. However, the nature of conflict is changing – and urban environments play an increasing role in military thinking. Cities are built exclusively for humans. A tracked robot cannot easily climb a vertical fire escape ladder, turn a standard door handle, squeeze through a narrow, debris filled stairwell, or sit in the driver’s seat of a captured supply truck. A humanoid robot acts as a “drop-in replacement” for a human soldier. If a building is designed for a human to navigate, a humanoid robot can navigate it without requiring custom redesigns or specialised ramps. This brings us to a profound ethical crossroads. Many of us in the robotics field do not endorse offensive warfare. But these machines have an undeniable utility in defensive scenarios and those concerned with neutralising threats to military personnel and civilians. Sending a humanoid into a building to rescue hostages, neutralising an active threat such as hostage-takers, or clearing a booby trapped room saves human lives. In fact, the modern surge in humanoid robotics was largely kickstarted by the US government’s Darpa Robotics Challenge, which funded bipedal robots specifically to respond to disasters such as the Fukushima nuclear meltdown where human responders could not survive. The dilemma is that the technology is agnostic to intent. The baseline capabilities required to navigate a ruined building and extract a casualty are the same capabilities needed to enter a building and kill enemy soldiers. If the technology is ready for defence, it is also ready for offensive use. Perhaps the most alarming aspect of this rapid advancement is how accessible it is. Unlike nuclear technology or stealth aircraft, modern robotics thrives on open-source frameworks. For example, a military specific software ecosystem (a network of apps and other services that work together) known as ROS-M, along with simulation tools and training datasets, are largely public and shared across global academic communities. With enough skill, a dedicated adversary can replicate advanced robotic behaviour with relative ease. We can no longer afford to treat humanoid robotics purely as an academic pursuit or a commercial novelty. We need an urgent international conversation about how to control these advances. Just as we regulate the export of certain microchips and aerospace components, we must begin protecting the software architecture and training pipelines that give these machines their minds. The hardware is walking out of the lab – it is time our policies caught up. Senior Lecturer, Department of Engineering, Nottingham Trent University Kartikeya Walia does not work for, consult, own shares in or receive funding from any company or organisation that would benefit from this article, and has disclosed no relevant affiliations beyond their academic appointment. Nottingham Trent University provides funding as a member of The Conversation UK. View all partners https://doi.org/10.64628/AB.6dpetxtxx Copyright © 2010–2026, The Conversation Media Group Ltd
Images (6): 

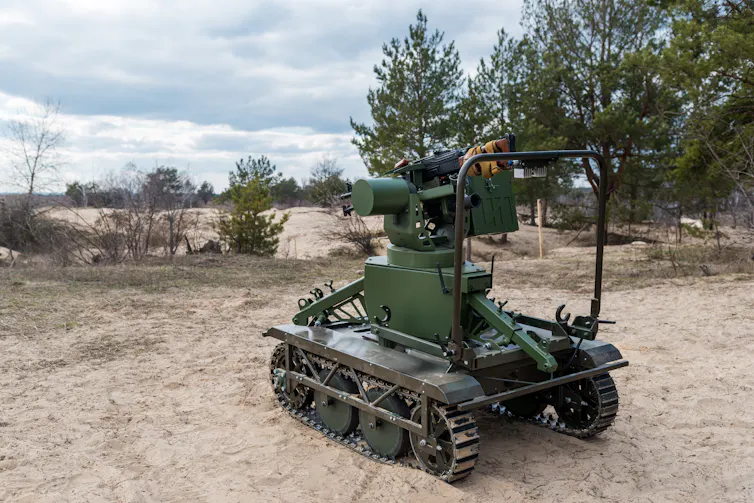

|
|||||
| Modelado y control de robots aéreos bioinspirados con técnicas de … | https://oa.upm.es/97915/ | 10 | Sep 23, 2026 00:03 | active | |
Modelado y control de robots aéreos bioinspirados con técnicas de aprendizaje por refuerzo | Archivo Digital UPMContent:
Los robots aéreos bioinspirados, capaces de reproducir estrategias de vuelo observadas en aves e insectos, ofrecen ventajas potenciales frente a los UAV convencionales en maniobras agresivas como el posado (perching). En este tipo de maniobras, el vehículo debe aproximarse a un objetivo y disipar gran parte de su energía cinética en una distancia muy reducida. El control de estos sistemas resulta especialmente complejo debido a su dinámica no lineal, al fuerte acoplamiento entre traslación y rotación, y a la variabilidad aerodinámica introducida por la morfología variable de sus alas y cola. Las técnicas clásicas de control, generalmente basadas en modelos linealizados, presentan limitaciones importantes en estas condiciones, lo que motiva el estudio de enfoques alternativos basados en aprendizaje por refuerzo. Este Trabajo Fin de Máster tiene como objetivo desarrollar y evaluar un entorno de modelado y control para un robot aéreo bioinspirado, aplicando técnicas de aprendizaje por refuerzo profundo para estudiar su capacidad de ejecutar maniobras de aproximación y posado. El trabajo parte del estudio de referencia de Wüest et al., adoptando una formulación longitudinal bidimensional simplificada que permite centrar el análisis en las variables principales de la maniobra: posición, velocidad, actitud de cabeceo y ángulo de ataque. Para ello, se implementó un entorno de simulación compatible con Gymnasium y Stable-Baselines3, en el que se definieron el espacio de observación, el espacio de acciones, la función de recompensa y las condiciones de terminación del episodio. Sobre este entorno se entrenaron y compararon dos algoritmos de aprendizaje por refuerzo: Proximal Policy Optimization (PPO) y Soft Actor-Critic (SAC). Además, se analizó la influencia de distintos márgenes de éxito sobre el comportamiento de control aprendido. Los resultados muestran que ambos algoritmos son capaces de aprender políticas de control exitosas para la tarea de posado, generando comportamientos físicamente coherentes: reducción de la velocidad de avance, aumento del ángulo de cabeceo y del ángulo de ataque en la fase final, y coordinación entre el empuje, el elevador y la morfología variable del ala y la cola. PPO ofrece un rendimiento sólido y estable para márgenes de éxito de referencia e intermedios, mientras que SAC demuestra mayor robustez y genera trayectorias más suaves y repetibles bajo condiciones terminales más estrictas. No obstante, se identifica como principal limitación que la velocidad final del vehículo se mantiene en torno a 4 m/s en la mayoría de los casos, por lo que la maniobra aprendida corresponde a una aproximación controlada y no a una detención completa en el punto de posado. En conjunto, este trabajo demuestra que el aprendizaje por refuerzo profundo constituye un marco válido y flexible para el estudio de estrategias de aproximación y posado en robots aéreos bioinspirados. Asimismo, sienta las bases para futuras extensiones hacia modelos tridimensionales más realistas, funciones de recompensa más avanzadas y una posible transferencia a plataformas reales. --ABSTRACT-- Bio-inspired aerial robots, which reproduce flight strategies observed in birds and insects, offer potential advantages over conventional UAVs in aggressive maneuvers such as perching. In these maneuvers, the vehicle must approach a target while dissipating a large part of its kinetic energy over a very short distance. Controlling these systems is particularly challenging due to their nonlinear dynamics, the strong coupling between translational and rotational motion, and the aerodynamic variability introduced by the variable morphology of their wings and tail. Classical control techniques, typically based on linearized models, present important limitations under these conditions, which motivates the study of alternative approaches based on reinforcement learning. The objective of this Master’s Thesis is to develop and evaluate a modeling and control environment for a bio-inspired aerial robot, applying deep reinforcement learning techniques to study its ability to perform approach and perching maneuvers. The work is based on the reference study by Wüest et al., adopting a simplified twodimensional longitudinal formulation that allows the analysis to focus on the main variables involved in the maneuver: position, velocity, pitch attitude, and angle of attack. To this end, a simulation environment compatible with Gymnasium and StableBaselines3 was implemented, defining the observation space, action space, reward function, and episode termination conditions. Two reinforcement learning algorithms were trained and compared in this environment: Proximal Policy Optimization (PPO) and Soft Actor-Critic (SAC). In addition, the influence of different success margins on the learned control behavior was analyzed. The results show that both algorithms are able to learn successful control policies for the perching task, generating physically coherent behaviors: reduction of forward velocity, increase in pitch angle and angle of attack during the final phase, and coordination between thrust, elevator deflection, and the variable morphology of the wing and tail. PPO provides solid and stable performance for the reference and intermediate success margins, whereas SAC shows greater robustness and produces smoother and more repeatable trajectories under stricter terminal conditions. However, the main limitation identified is that the final vehicle velocity remains around 4 m/s in most cases, meaning that the learned maneuver corresponds to a controlled approach rather than a complete stop at the perch. Overall, this work demonstrates that deep reinforcement learning provides a valid and flexible framework for studying approach and perching strategies in bio-inspired aerial robots. It also establishes a foundation for future extensions toward more realistic three-dimensional models, improved reward functions, and possible transfer to real robotic platforms. El Archivo Digital UPM es el repositorio digital institucional mantenido por la Biblioteca de la Universidad Politécnica de Madrid. Desarrollado y gestionado con EPrints. Sindicación: Atom, RSS 2.0 y RSS 1.0 (HTML) Recolección: OAI 2.0 El Archivo Digital UPM es el repositorio digital institucional mantenido por la Biblioteca de la Universidad Politécnica de Madrid. Desarrollado y gestionado con EPrints. Sindicación: Atom, RSS 2.0 y RSS 1.0 (HTML) Recolección: OAI 2.0
Images (10): 


|
|||||